Continuum robotics
 Research
Ongoing · WPI MER Laboratory
Mapping actuation to shape and motion
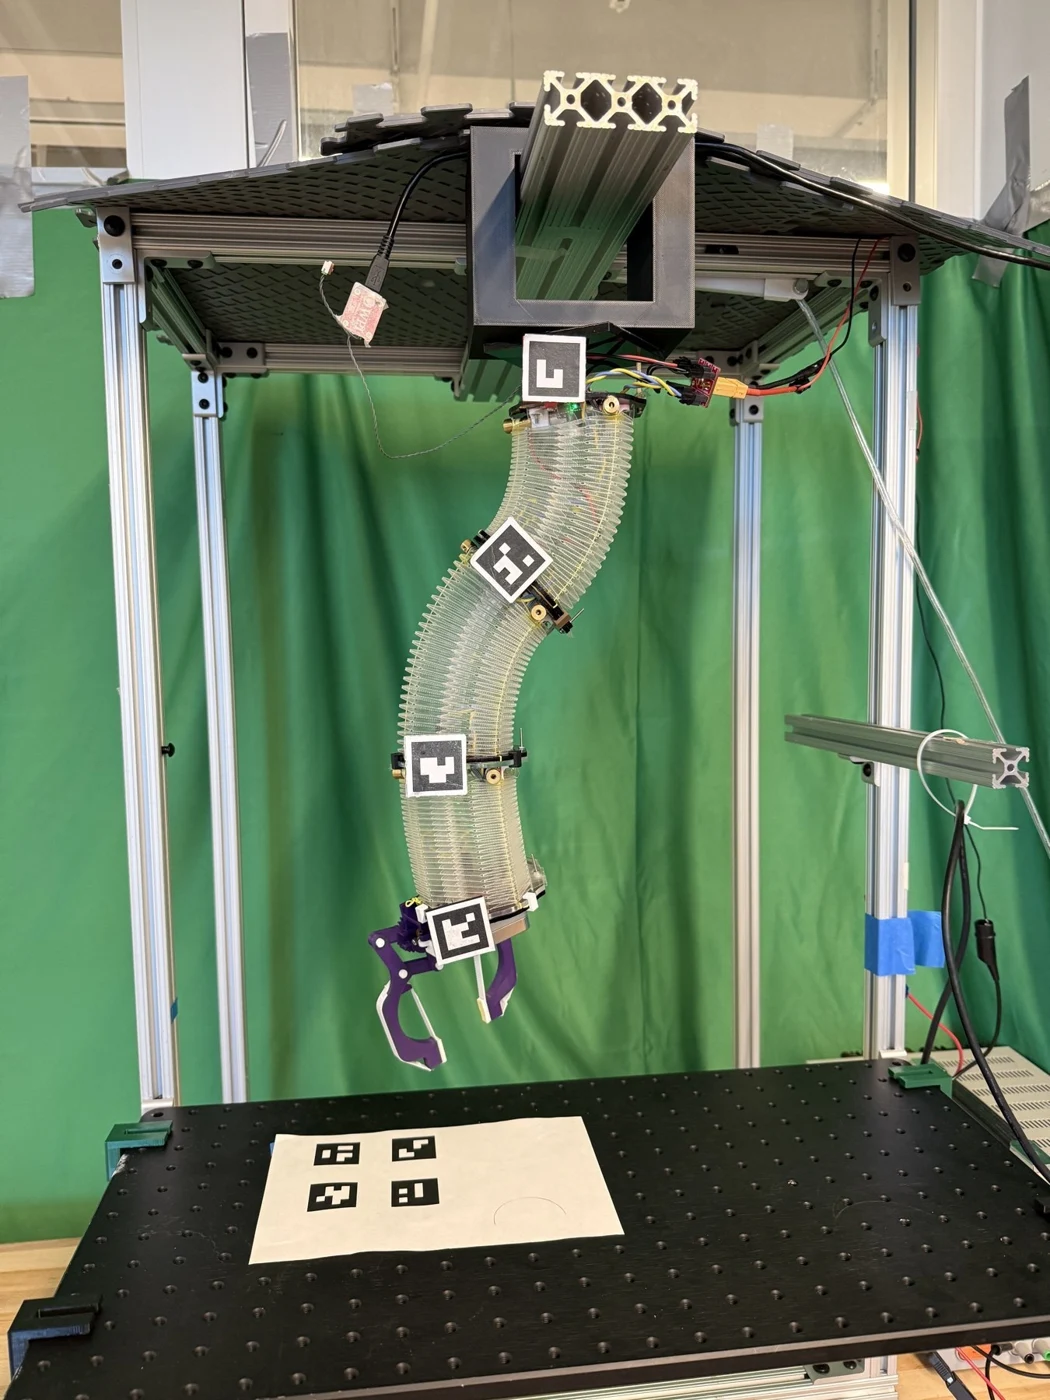
Research into how tendon actuation maps to the motion and force capabilities of soft continuum robots, accounting for nonlinear behavior and model uncertainty.
System architecture
- 01Tendon lengths
- 02Constant-curvature shape
- 03Cartesian backbone
- 04Manipulability
Kinematic modeling
At WPI's Manipulation and Environmental Robotics Laboratory, I am developing Python simulations for single- and multi-section forward kinematics. The modeling approach maps tendon lengths to piecewise constant-curvature shape and then to the Cartesian backbone.
Differential motion
I am deriving Jacobians between actuator, shape, and Cartesian spaces to characterize manipulability: the relationship between tendon actuation and achievable motion and force.
Visual feedback & experimental learning
Current work includes studying computer vision and image-based visual servoing for full-body shape feedback, and investigating manipulability ellipsoids learned from experimental data. These are ongoing research directions, not claims of a completed validated control system.