BB-8
 Independent robotics
Integrated prototype
From perception to motion
A spherical robot integrating mechanical packaging, embedded motor control, wireless communication, and camera-based perception. Designed in CAD, built in hardware, and evaluated through separate vision and motion demonstrations.
System architecture
- 01Camera + Raspberry Pi
- 02MobileNet detection
- 03KCF tracking
- 04Wi-Fi / UDP
- 05ESP32 + motor drive
See the system in motion
Vision pipeline
MobileNet detection and KCF tracking on the Raspberry Pi.
Open on YouTube ↗Integrated motion
Physical motion of the assembled mechanical, electrical, and embedded-control system.
Open on YouTube ↗Engineering a robot inside a sphere
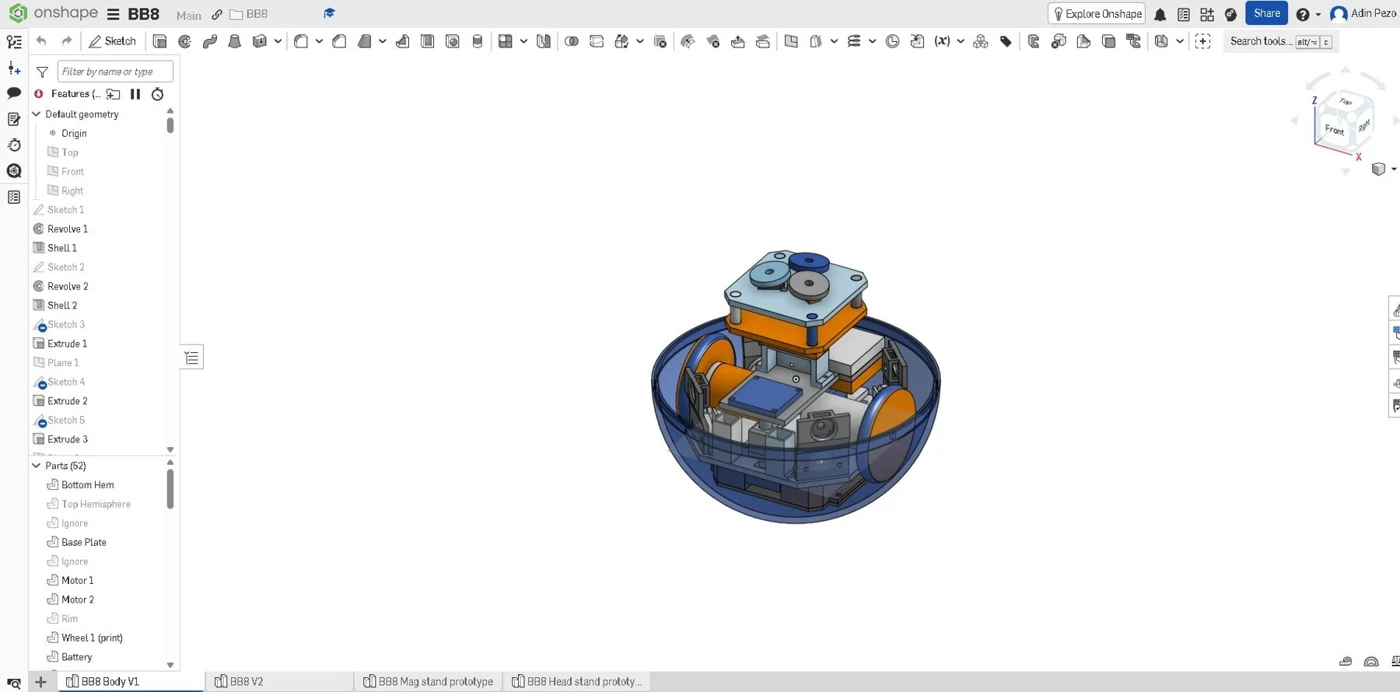
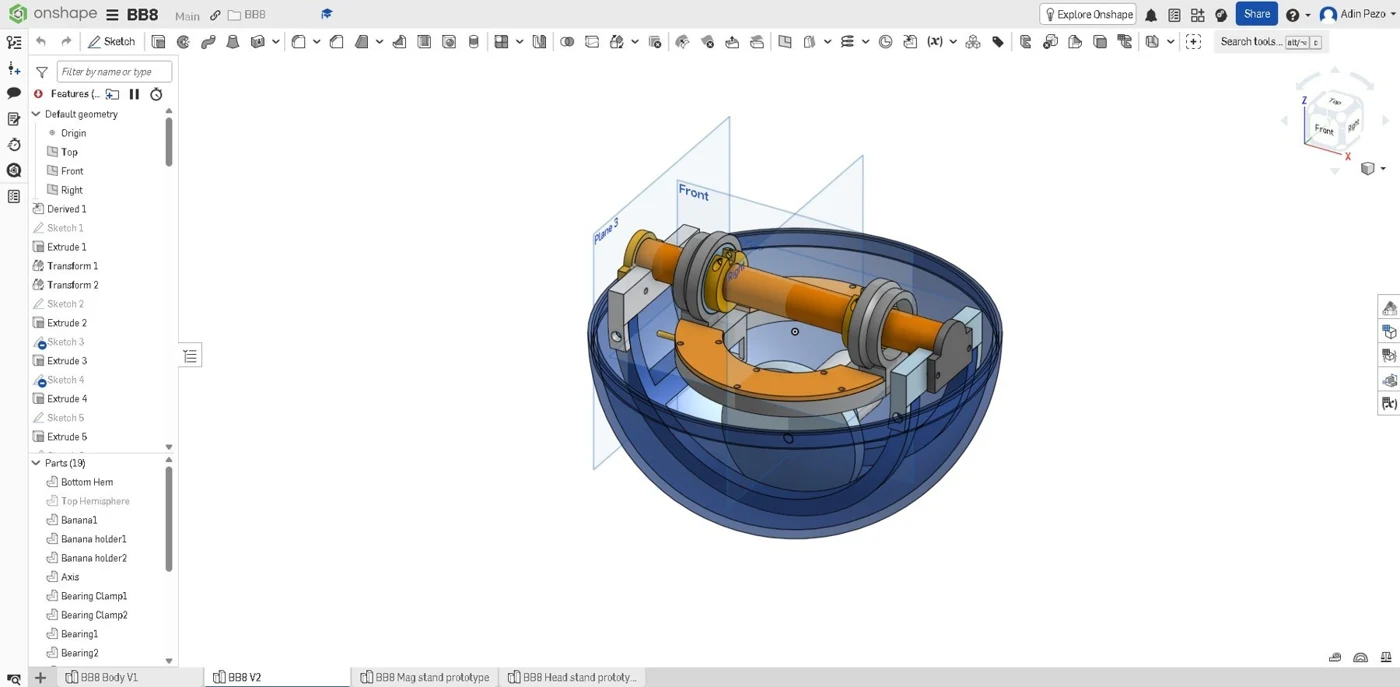
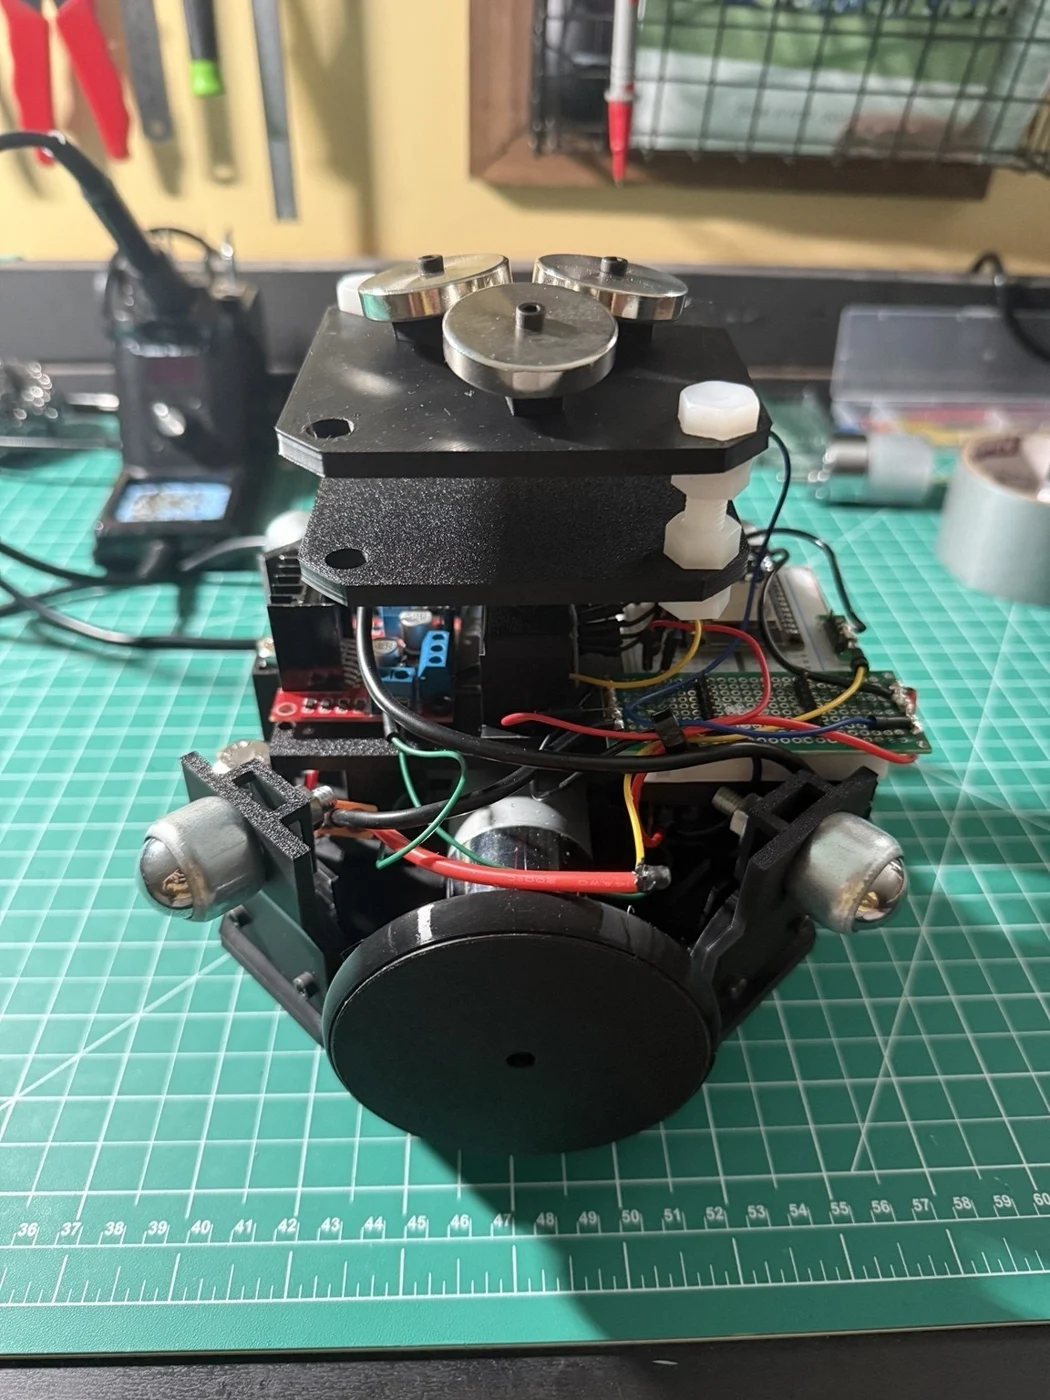
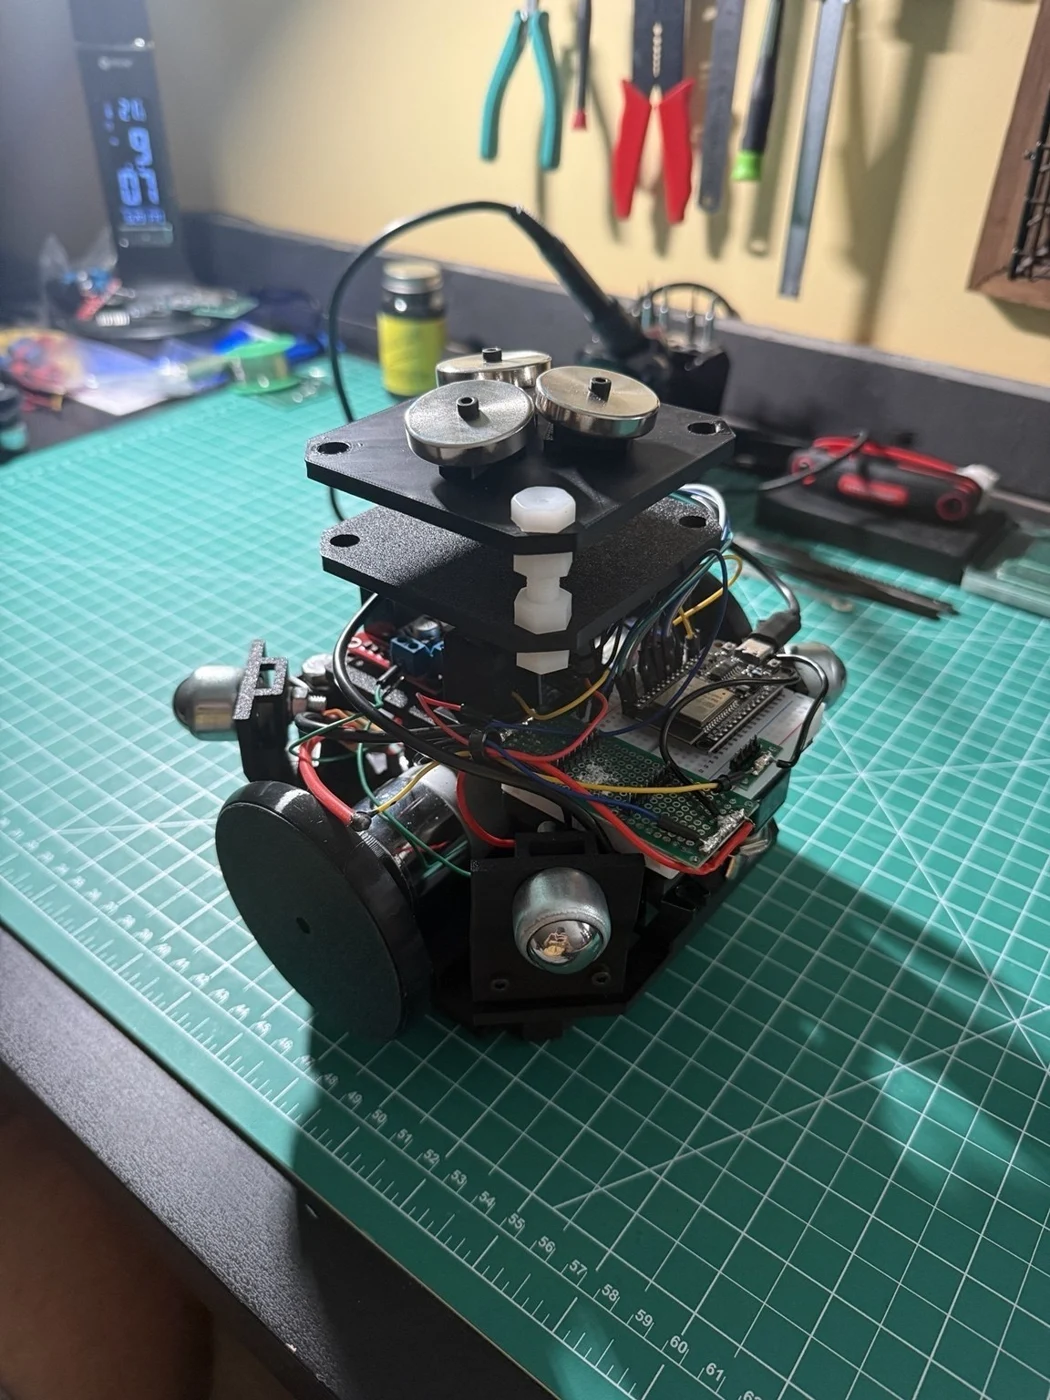
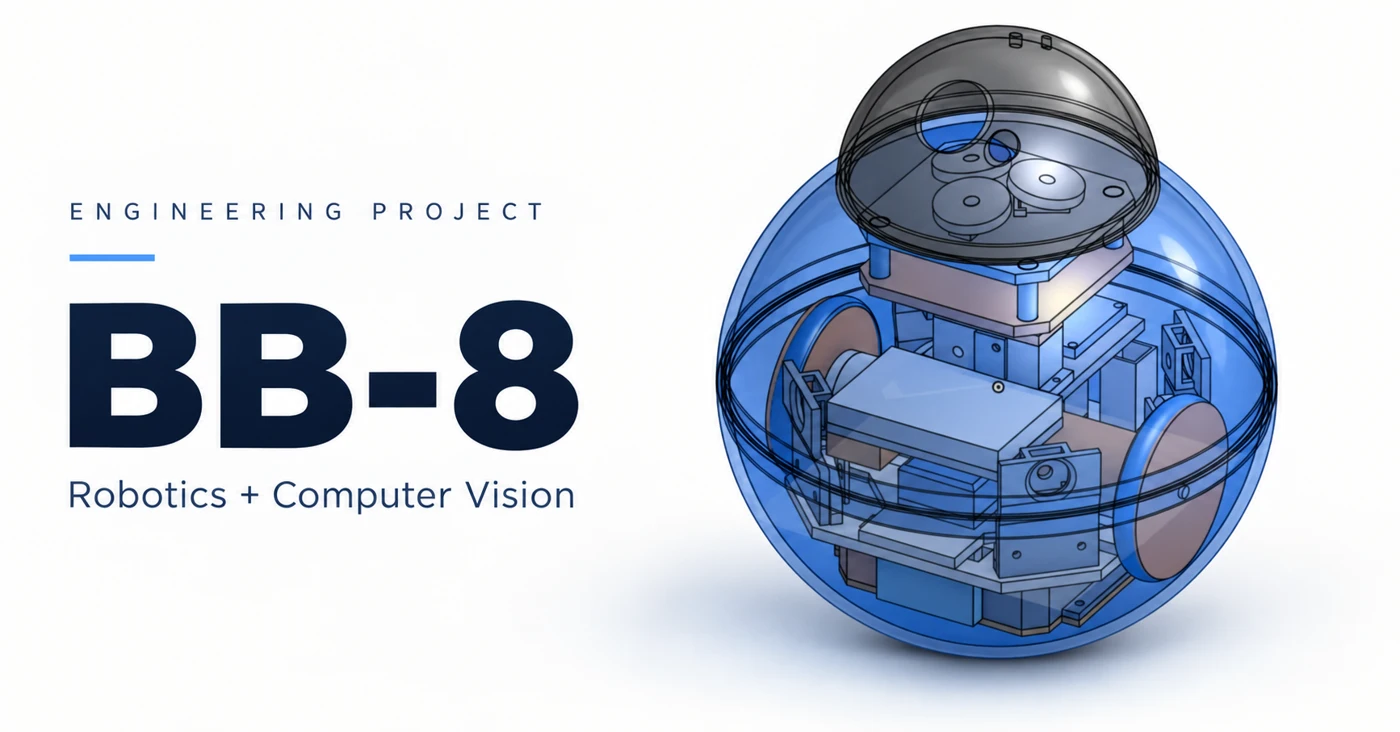
I iterated the internal drive architecture and component packaging in Onshape, then translated the design into an assembled mechanical and electrical system. The two CAD revisions document the evolution of the mechanism; the hardware photographs show the drive assembly, electronics, and magnetic head interface.
Embedded control & communication
I developed ESP32-based C++ motor-control software with gamepad input, IMU integration, and differential-drive logic. A Raspberry Pi handles the camera pipeline, with Wi-Fi/UDP communication connecting perception to the embedded controller. The GitHub project also includes Bluepad32 resources for Bluetooth controller connectivity.
Detection, then tracking
The vision pipeline combines MobileNet object detection with KCF tracking in OpenCV. Detection establishes the target location; tracking follows it between frames. This separates target acquisition from temporal tracking and provides a practical basis for observing the robot's motion.
Demonstrated integration
The videos document the Raspberry Pi vision pipeline and integrated mechanical motion. These are prototype demonstrations rather than a quantified autonomy benchmark: tracking accuracy, response time, drift, and motion repeatability are not reported as measured results.
Design & hardware